June 2026
Two AUVs Navigate Cooperatively While Submerged
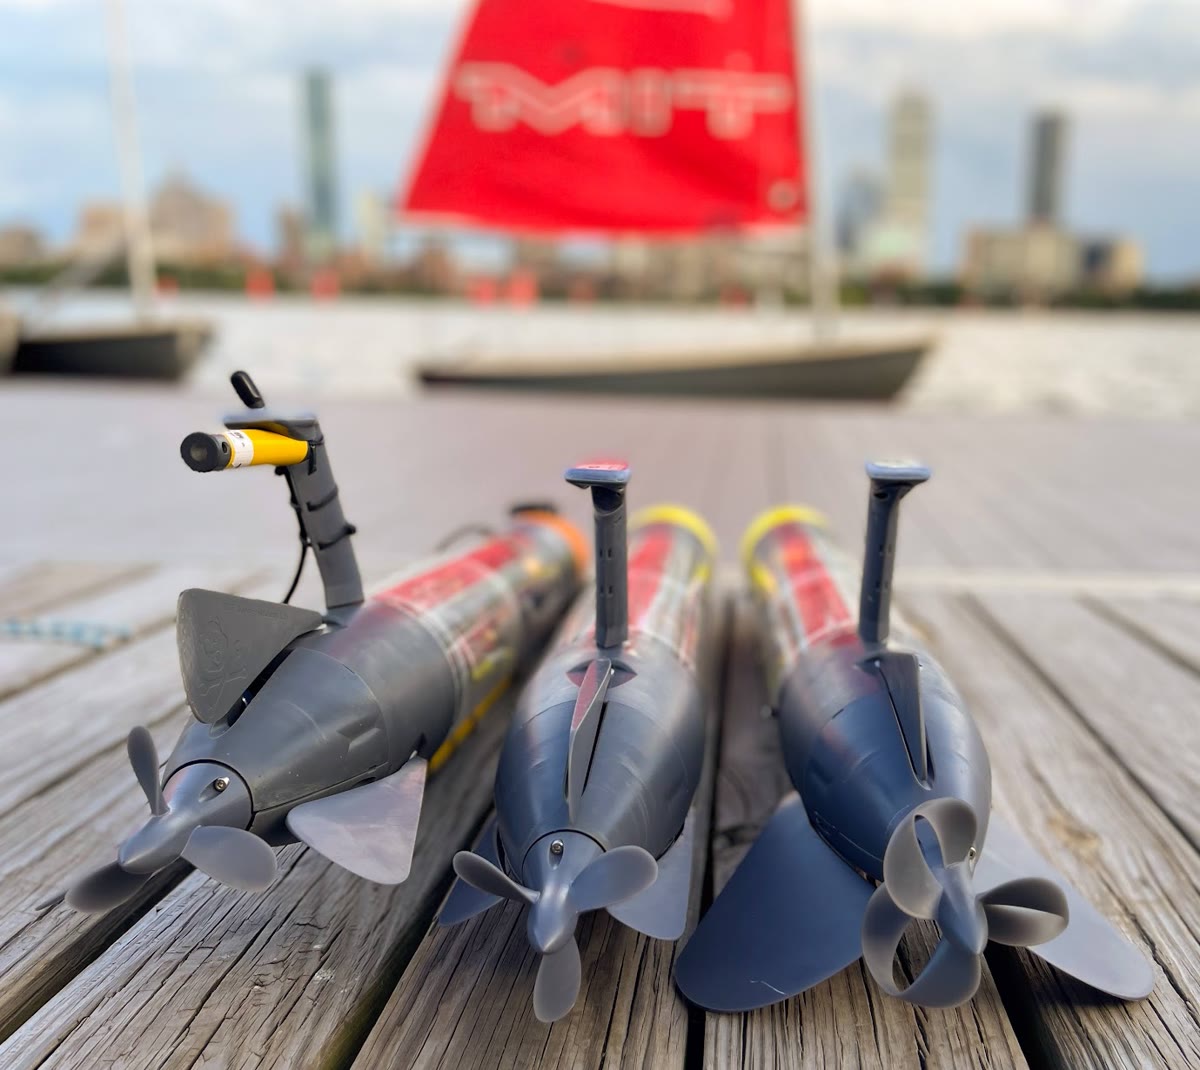
Two Spurdog AUVs operated fully submerged at the same time on the Charles River, exchanging live inter-vehicle acoustic ranges and building a joint factor graph online to reach roughly 1.3 m of terminal position error in a GNSS-denied environment.
May 2026
Website Launch
The Spurdog project website and collaborator portal are now live.
January 2026
Vehicle Tested to 400 Meters
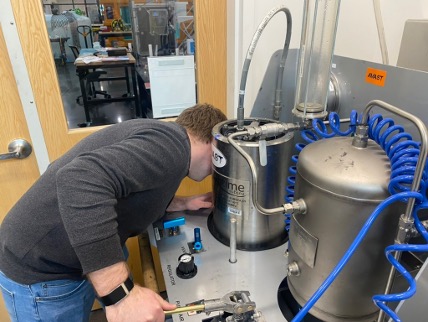
Vehicle design updated and tested to 400 meters depth at DeepTech at Woods Hole Oceanographic Institution.
October 2025
ASV-Aided AUV Navigation at IROS 2025
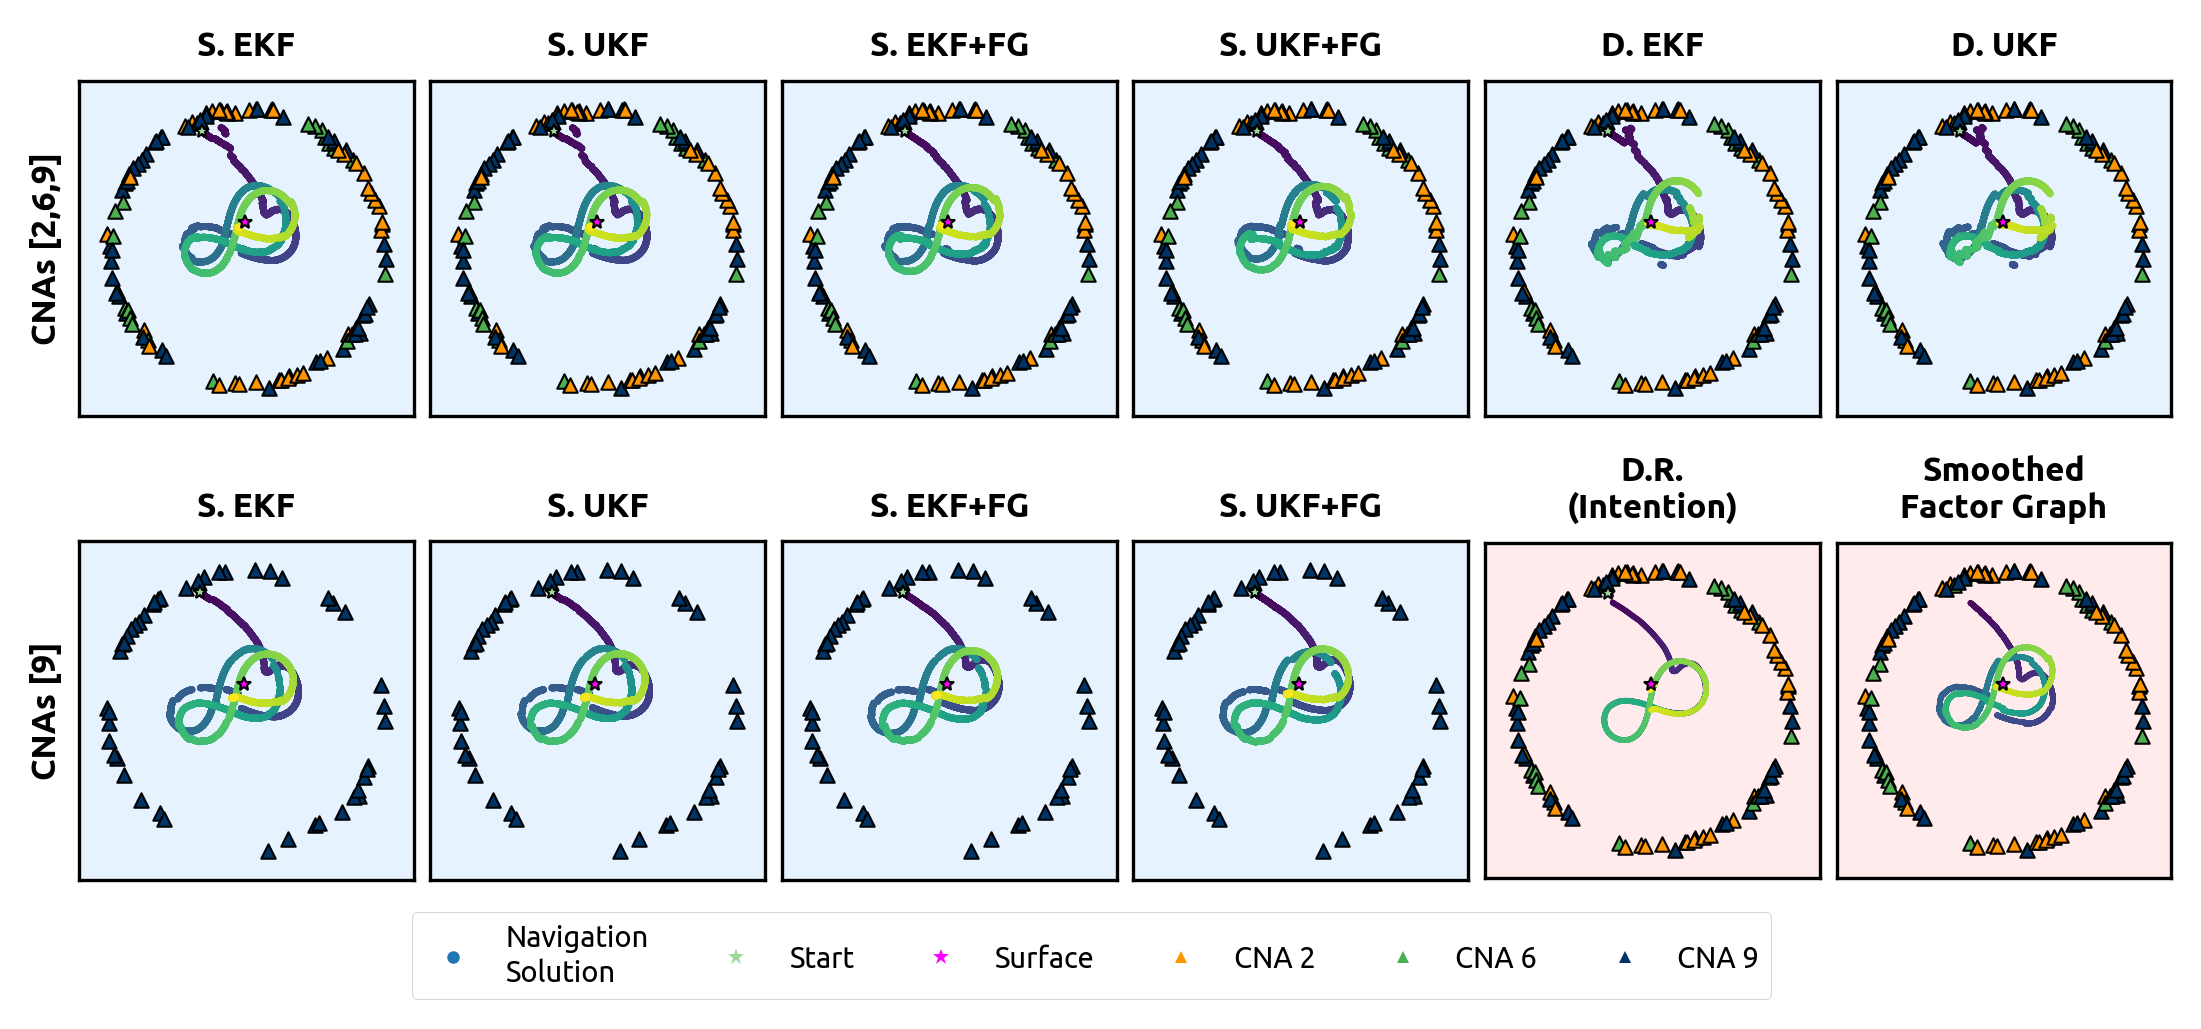
A field study on the Charles River demonstrated autonomous surface vehicles acting as mobile acoustic references to bound the drift of a submerged Spurdog, presented at the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2025.
September 2025
Toroidal Propeller Study at OCEANS 2025
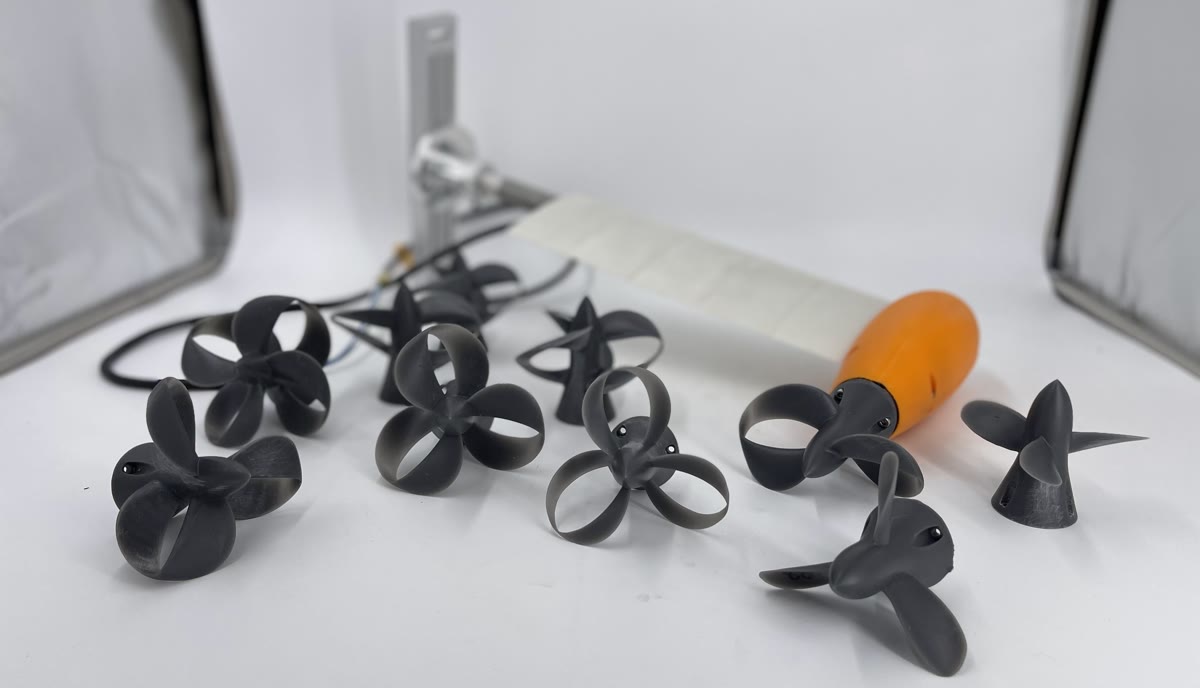
A study characterizing 3D-printed toroidal propellers against conventional OpenProp designs on the Spurdog platform, measured at the MIT Sea Grant tow tank, was presented at OCEANS 2025.
September 2024
Modular Trident Tailcone at OCEANS 2024
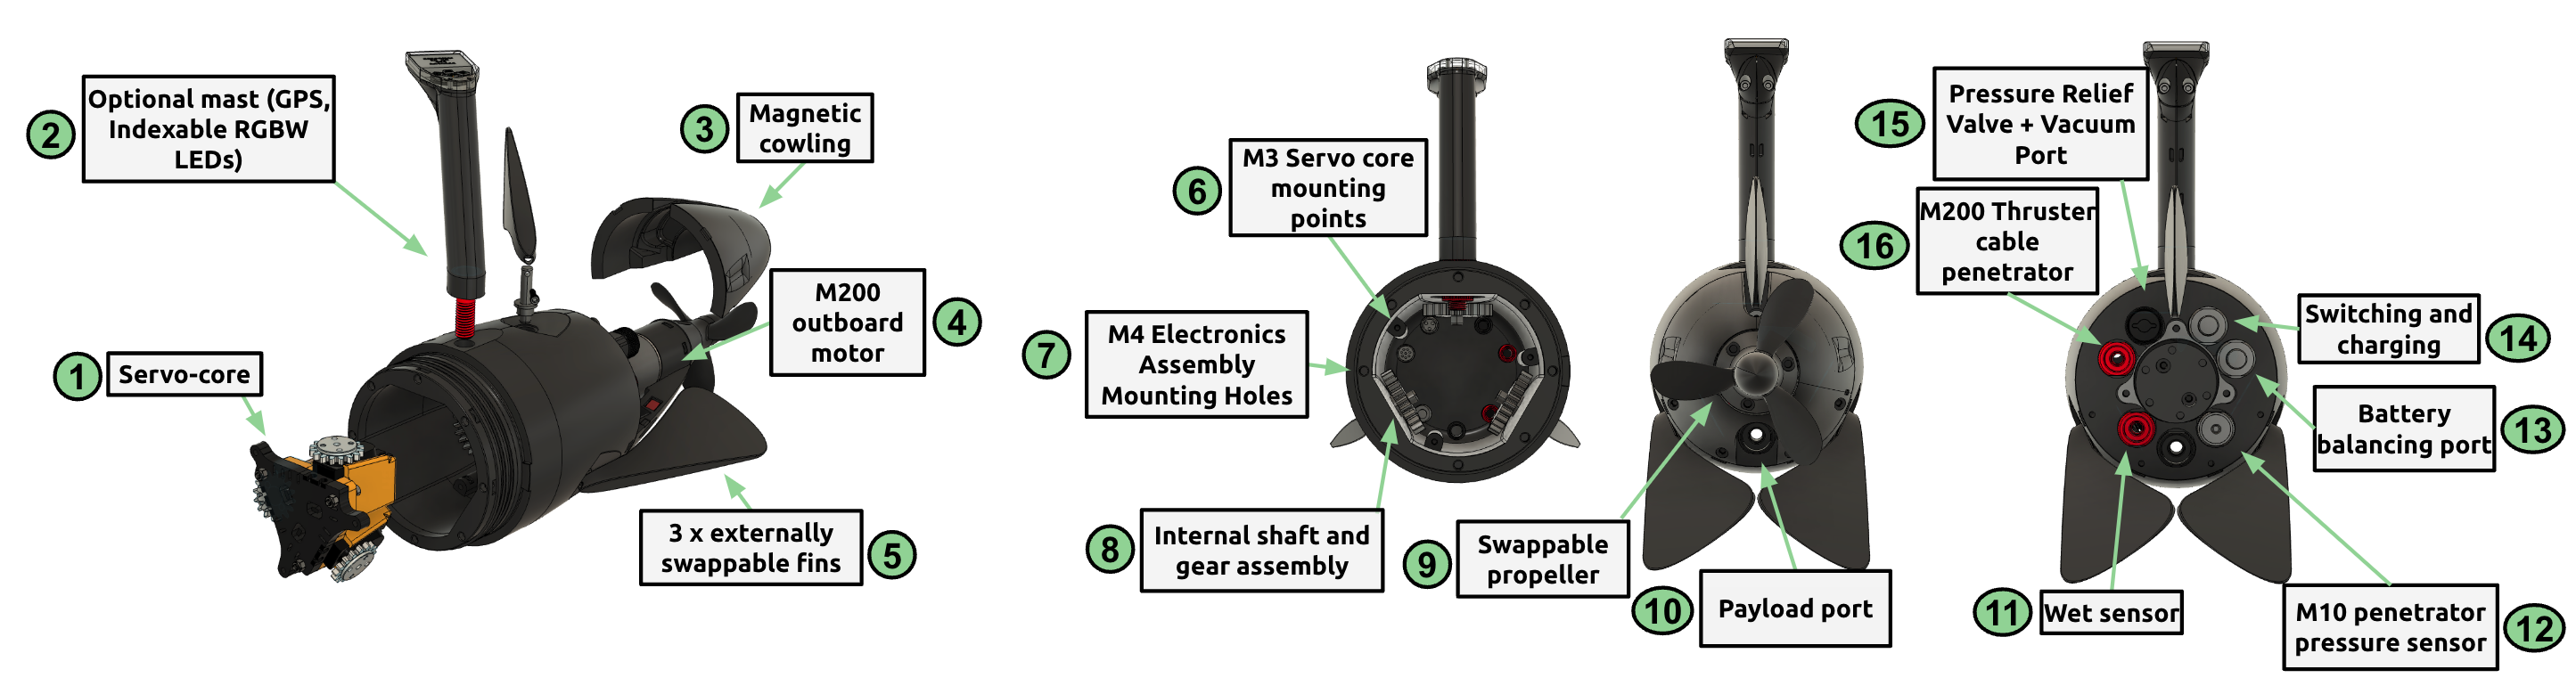
The Trident series of tailcones — a modular, field-configurable three-axis aft section fielded across multiple AUV platforms — was presented at OCEANS 2024 in Halifax.
September 2024
Spurdog Platform Paper at IEEE/OES AUV 2024
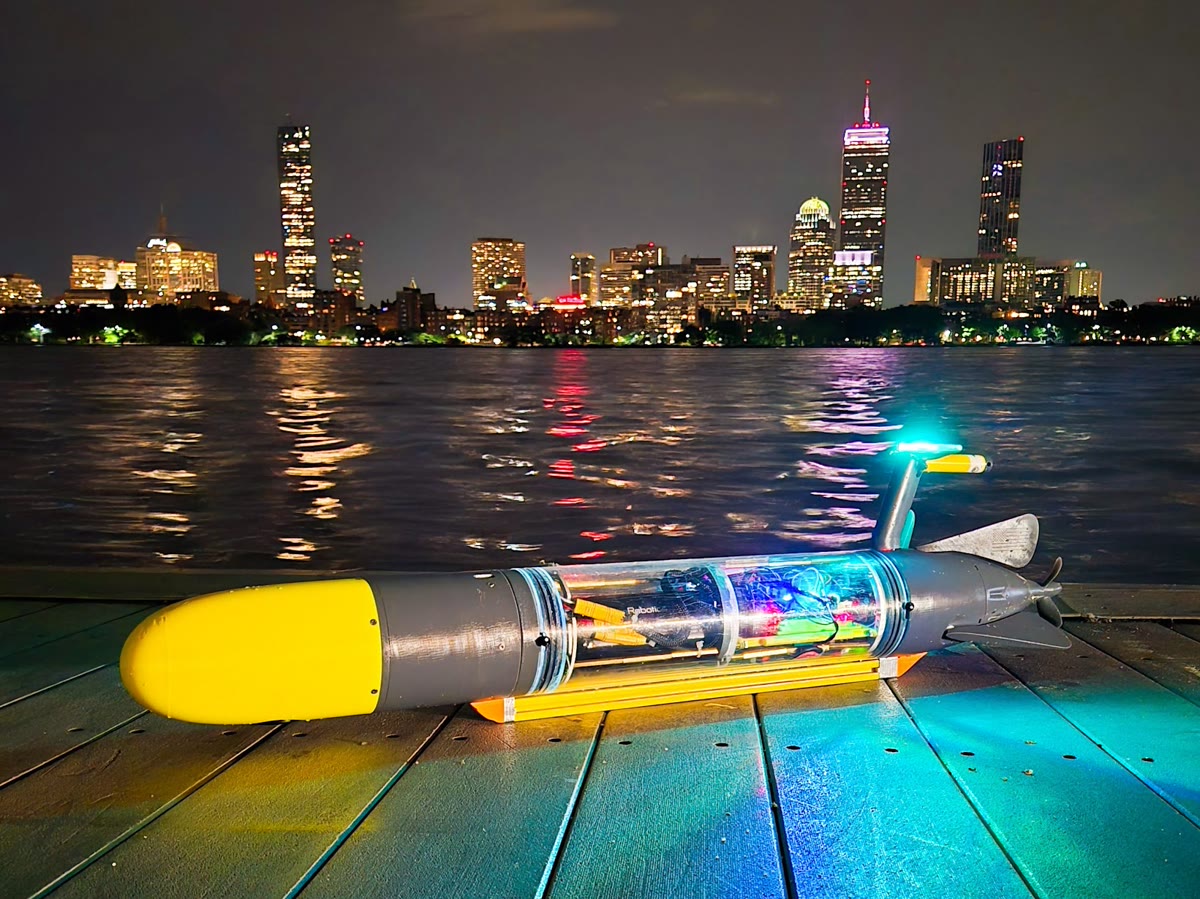
The Spurdog AUV — a low-cost, field-configurable platform built from commercial and 3D-printed parts — was introduced at the IEEE/OES Autonomous Underwater Vehicles Symposium (AUV) 2024.
April 30, 2024
First Flight
Spurdog's first deployment and swim test.